Zimo Li

I’m a computer science student at the University of Michigan. I work on machine learning for robots: world models, vision-language-action policies, and reinforcement learning. I’m looking for a Summer 2027 internship.

Off the clock

0best 0

Tempo70%

Click the game, then press the key shown on each note as it arrives (⇧ means hold Shift). The keys play like a piano; the sax shows the fingering. On a phone, tap.

Education

Expected Jun 2028

Bachelor of Science in Computer Science

  • University of Michigan, Ann ArborTransferred as a junior
  • Nanjing UniversityGPA 4.58/5.0, ranked top 6.7%

Selected coursework3D Robot Perception, Operating Systems, Deep Learning, Probability and Statistics

Experience

Oct 2025 – Apr 2026

Research Assistant

Learning And Mining from DatA (LAMDA) Laboratory

  • Machine learning and embodied AI research on Vision-Language-Action (VLA) robot foundation models.
  • Reproduced Google DeepMind’s Genie on robot video to test whether a self-supervised world model still recovers controllable latent actions when actions are continuous; it does. Implemented it in PyTorch, cross-checked it against an independent JAX version (Jafar), and trained it in a 6-day, 8-GPU RTX 5090 run with PyTorch Distributed Data Parallel (DDP).
  • Fine-tuned the π₀ (pi-zero) VLA base model on the LIBERO robotics benchmark.

Sep 2025 – Jun 2026

Core Team Member

University Student AI Association (AIA)

  • One of 18 members of the club’s 2025 core team; gave a lecture to members on flow matching.

Jul 2025 – Aug 2025

Software Engineering Intern

Archermind Technology

  • Independently designed, built, and deployed a Retrieval-Augmented Generation (RAG) desktop semantic search tool for an open-source operating system project hosted on Gitee; merged into the project’s Sep 2025 release.
  • Helped debug a humanoid robot on the physical platform alongside the operating system team.

Sep 2024 – Jun 2025

Project Lead

University Student Innovation Program

  • Led a student team building a RAG legal question-answering assistant on large language models (LLMs); against a no-retrieval baseline, the gain from retrieval turned negative as models improved, so recommended retiring it.

Honors

2026

Discover Citadel & Citadel Securities, Hong Kong

Around 50 students invited across Asia-Pacific; market-making simulation and coding challenge.

Jan 2025

Honorable Mention, Team Leader · Mathematical Contest in Modeling (MCM)

Predicted Olympic medals with a random forest (out-of-sample R² = 0.93), regression, and Gaussian mixture clustering.

2021 & 2022

First Prize (Top 1.5%) · National Olympiad in Informatics in Provinces (NOIP)

Timed C++ algorithm contest, scored on hidden tests under strict time and memory limits.

Projects

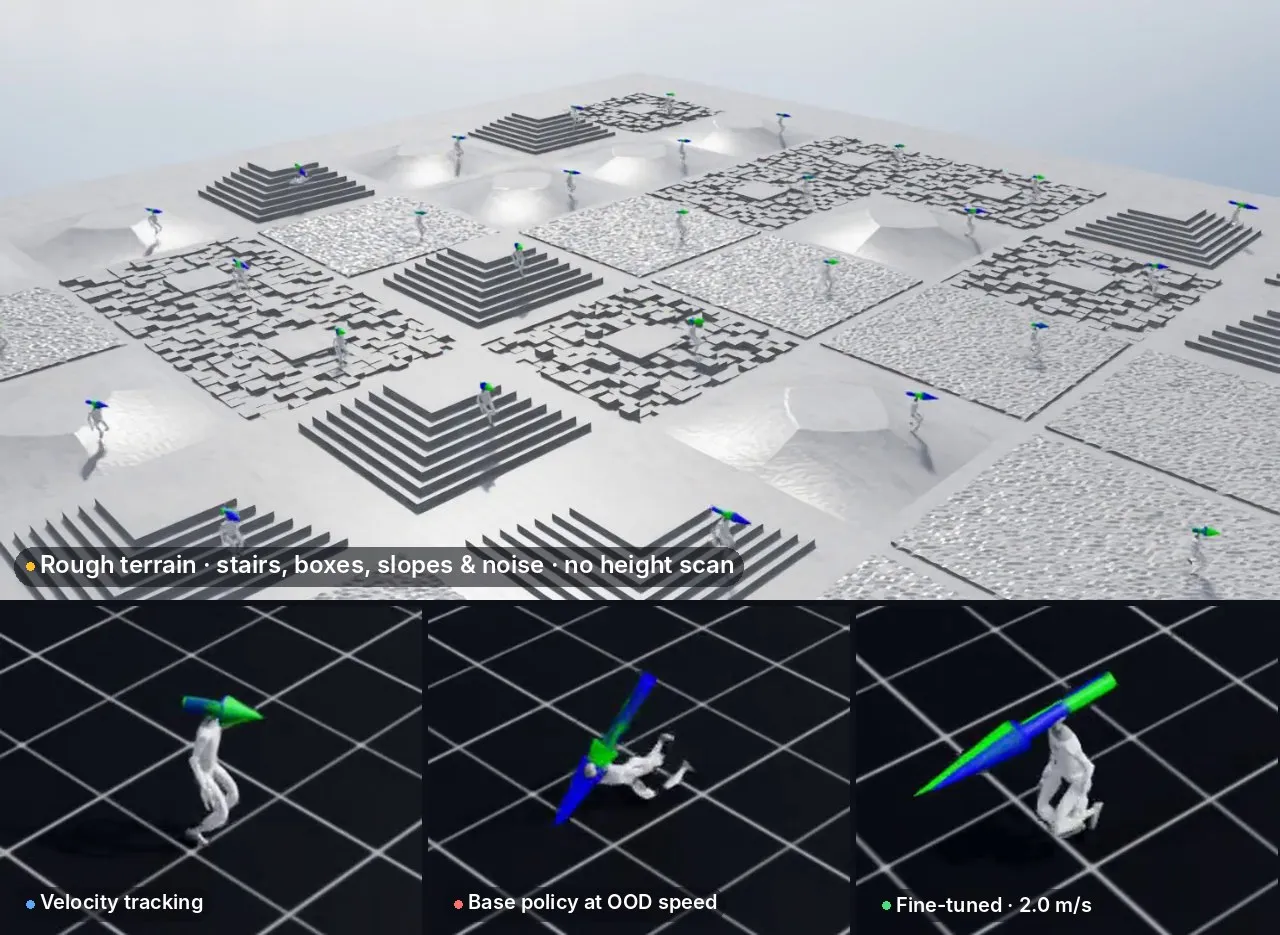
Simulated G1 humanoid robots walking over stairs, boxes and slopes.

Course project

Unitree G1 Humanoid Locomotion

  • Trained a Proximal Policy Optimization (PPO) walking policy in Isaac Lab across 4,096 parallel environments.
  • Fine-tuned it from a 1.3 m/s limit to 2.0 m/s, then onto stairs and slopes using proprioception alone.
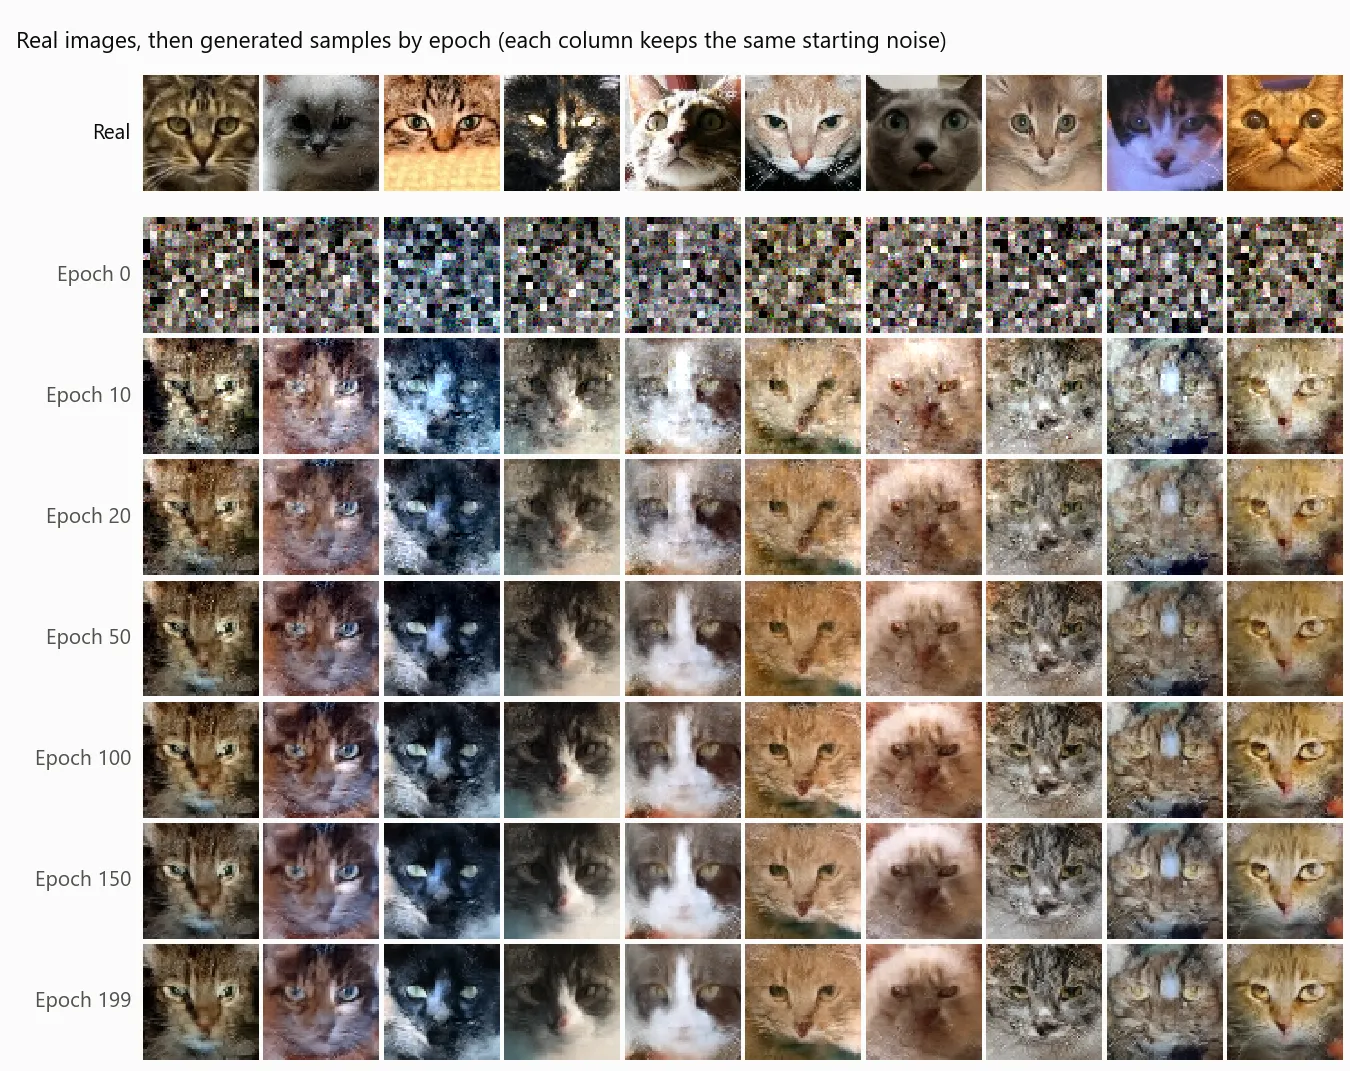
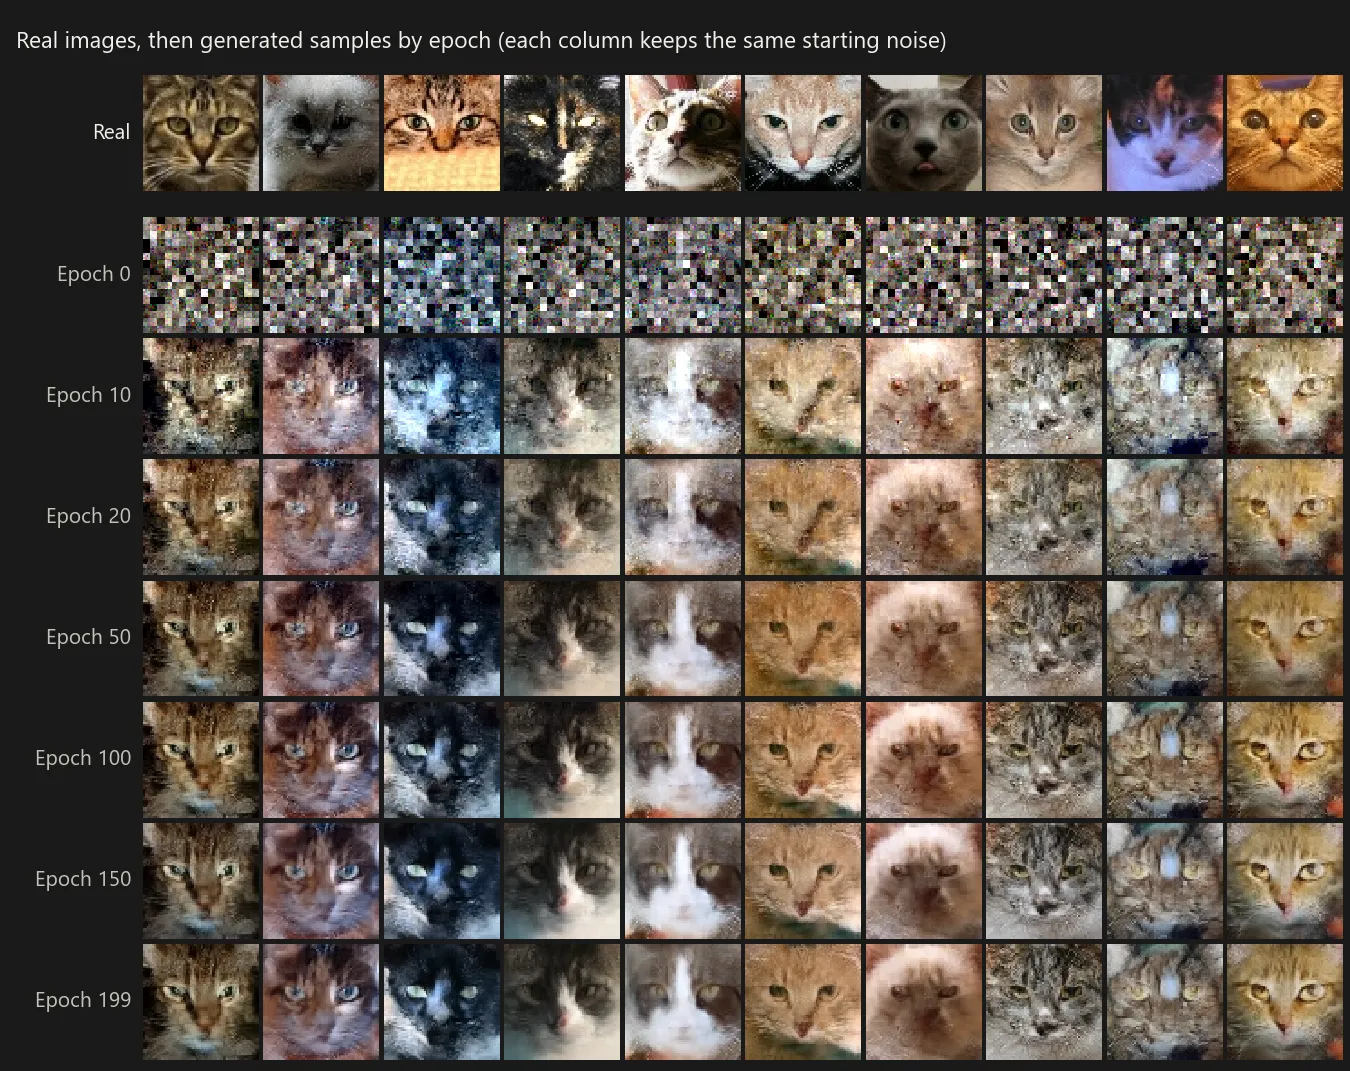
Grid of cat faces: real images, then generated samples from epoch 0 to 199. Noise becomes recognizable cat faces.Grid of cat faces: real images, then generated samples from epoch 0 to 199. Noise becomes recognizable cat faces.

Teaching code and tutorial

Flow Matching Diffusion Transformer

  • Teaching code and step-by-step tutorial for the AIA lecture on flow matching.
  • Minimal PyTorch Diffusion Transformer (DiT); 200 epochs on one RTX 4090 generate 64×64 cat faces.